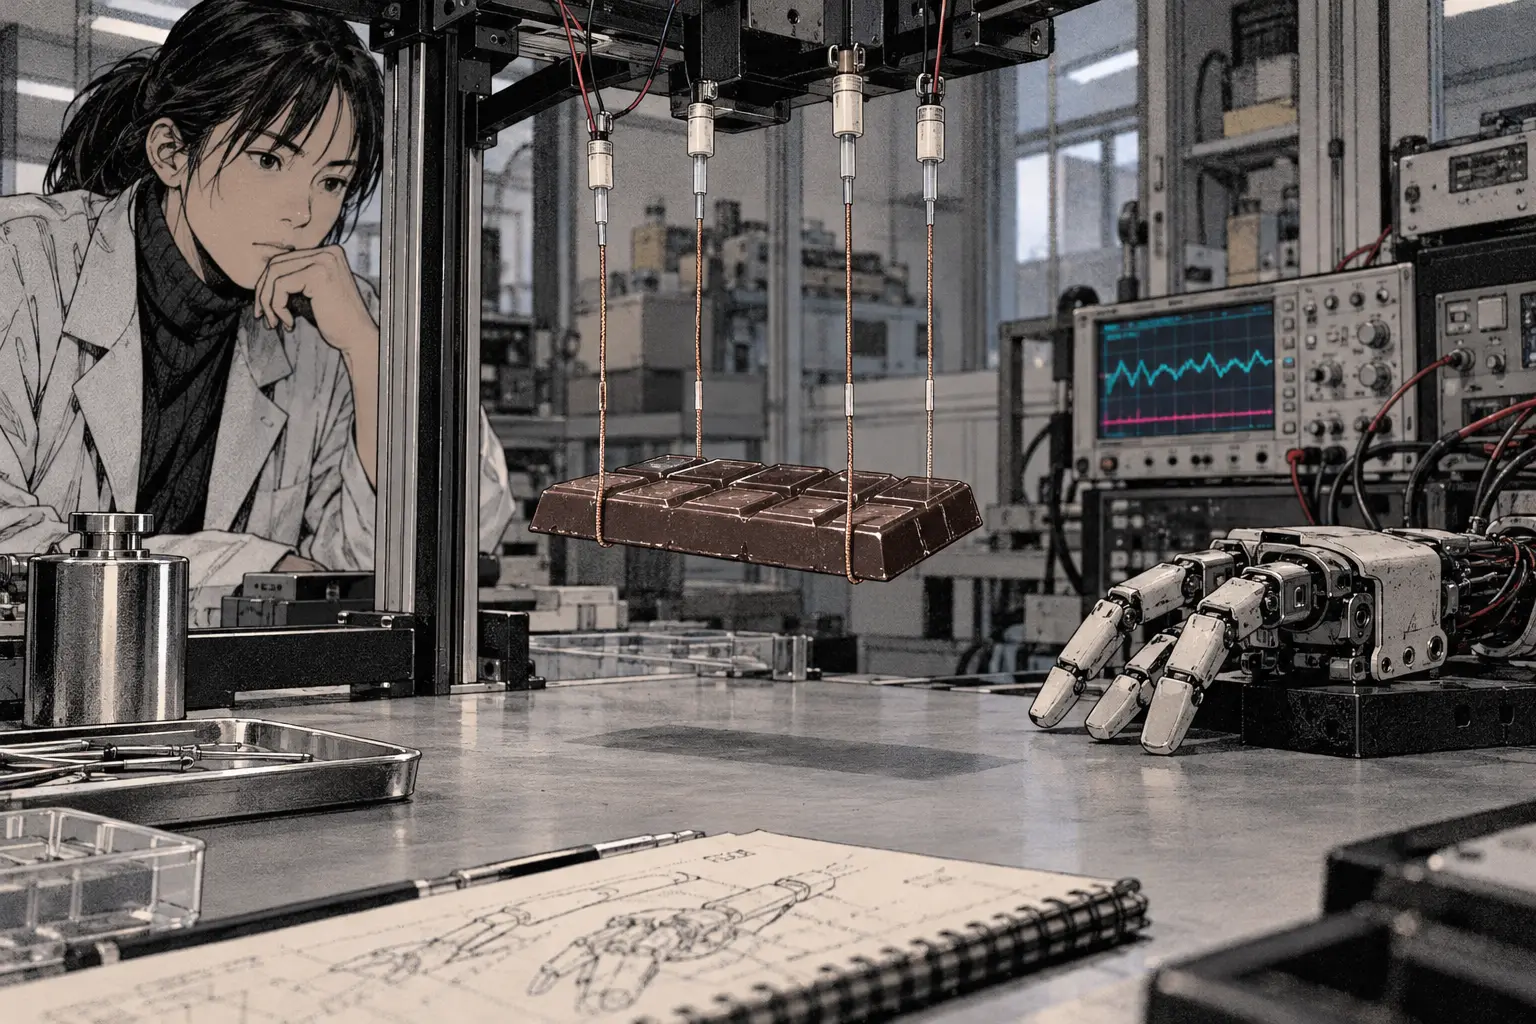
Four flexible fiber motors lifted a 46-gram chocolate bar in laboratory testing, while an individual motor supported a stationary load equivalent to about 75 grams.
The EPFL-developed FiberMotor measures between 1 and 3 millimeters in diameter. Its thin, flexible form is intended for soft-bodied machines, where adding a rigid motor could undermine pliability, according to New Atlas.
Each actuator consists of two concentric, hollow polymer fibers. A narrower fiber sits inside a wider outer tube, and thin copper wire is wound tightly around each fiber to form electrodes. When electrical current is applied, electrostatic forces repeatedly pull the fibers into alignment, causing the inner fiber to slide within the outer one. That motion provides a pulling force.
In addition to lifting the chocolate bar, a four-motor bundle flexed a tendon-driven robotic finger. The report provides no measurements for the finger’s movement, applied force or response time.
The motor has no gears or transmission and is back-driveable. According to New Atlas, that means it will not lock up when pushed by an external opposing force. The researchers hope to integrate the motors into mobility-assisting clothing, virtual-reality haptic systems and lightweight prosthetic devices.
The report provides no operating voltage, power consumption, stroke length, speed, actuator length, efficiency, cycle life or duty cycle. The individual motor’s 75-gram result concerns support of a stationary load, rather than repeated lifting at a measured speed. Durability and performance are still being improved through the spin-off company Elecsyor.
The reported tests do not establish performance in a complete wearable or mobile robot, and no messy-world deployment results are provided. The work, published in Advanced Materials, demonstrates linear pulling force from a flexible, millimeter-scale actuator, while performance under practical workloads remains unreported.